Cognitive robotics - Ridgeback simulation
Leader Following
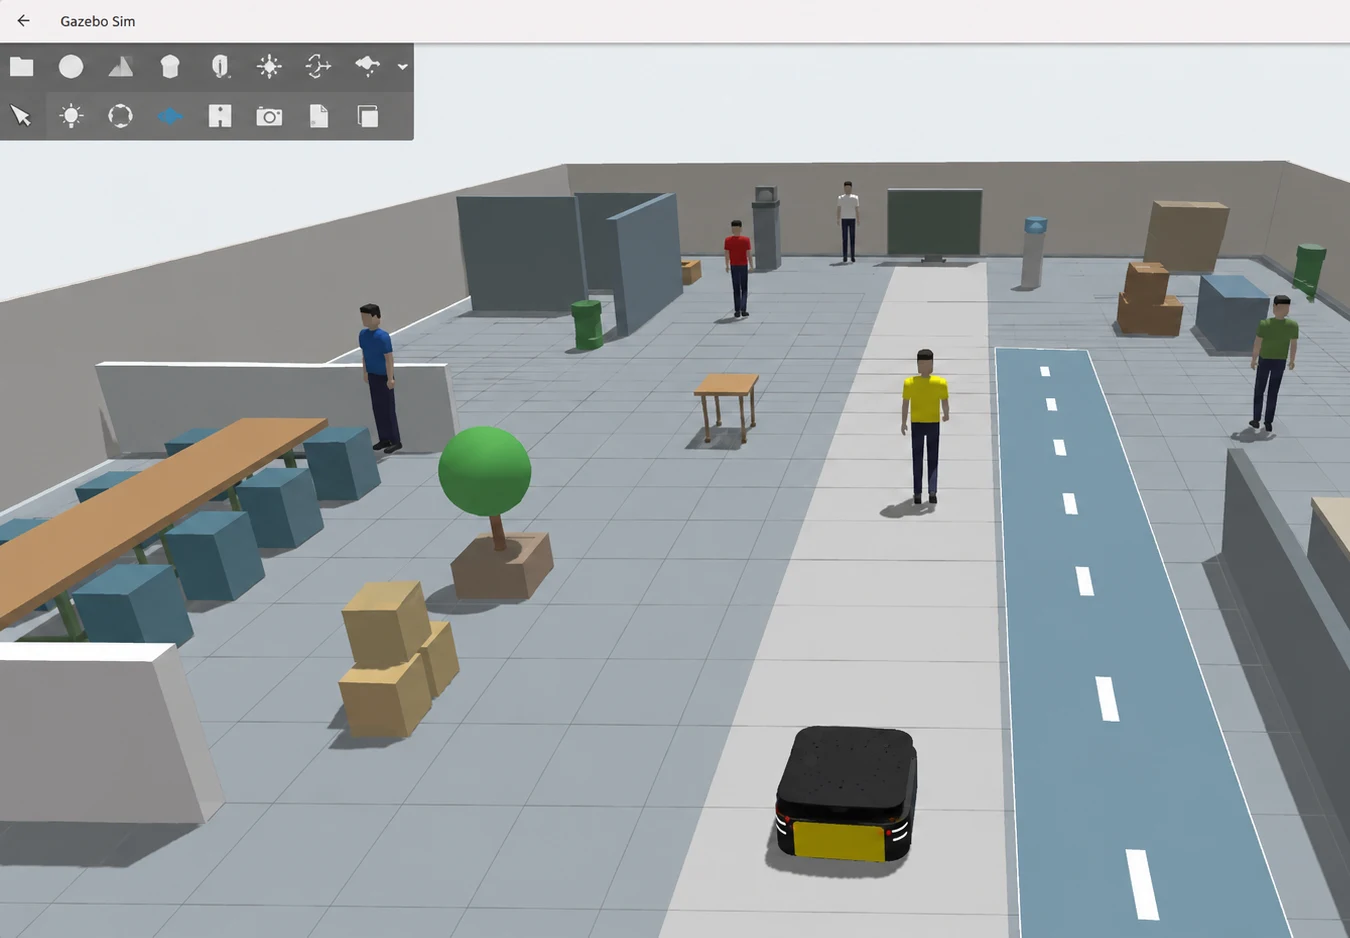
Ridgeback leader-following experiments that pick a chosen person out of a crowded scene and follow them through clutter - fusing camera-based detection with point-cloud perception to track the leader and visualize the intended follow path in RViz.
Research question
Can a mobile base reliably single out and follow one designated person in a cluttered, multi-person scene using color-cued detection and 3D point clouds?
Experiment log
Sustained following through a corridor
The second real-world milestone takes the Ridgeback out of the open lab and along a narrower route. The robot follows the designated person through a doorway and down a corridor while the inset perception view continues to localize the leader.
Outcome·The longer run demonstrates continuous target tracking and robot motion across changing room geometry and a constrained hallway.
Milestones
06/06About